Autonomous vehicles and robotics
LiDAR, multi-sensor and robotics annotation for perception teams, including hands-on LiDAR QA and correction on MCAP data as used with Foxglove.
Who it is for

AV and ADAS perception teams, robotics and embodied AI groups, physical AI data platforms, and LiDAR and mapping companies that need careful 3D labels at volume.
Typical problems

Perception data is multi-sensor, temporal and full of rare cases. Typical problems include:
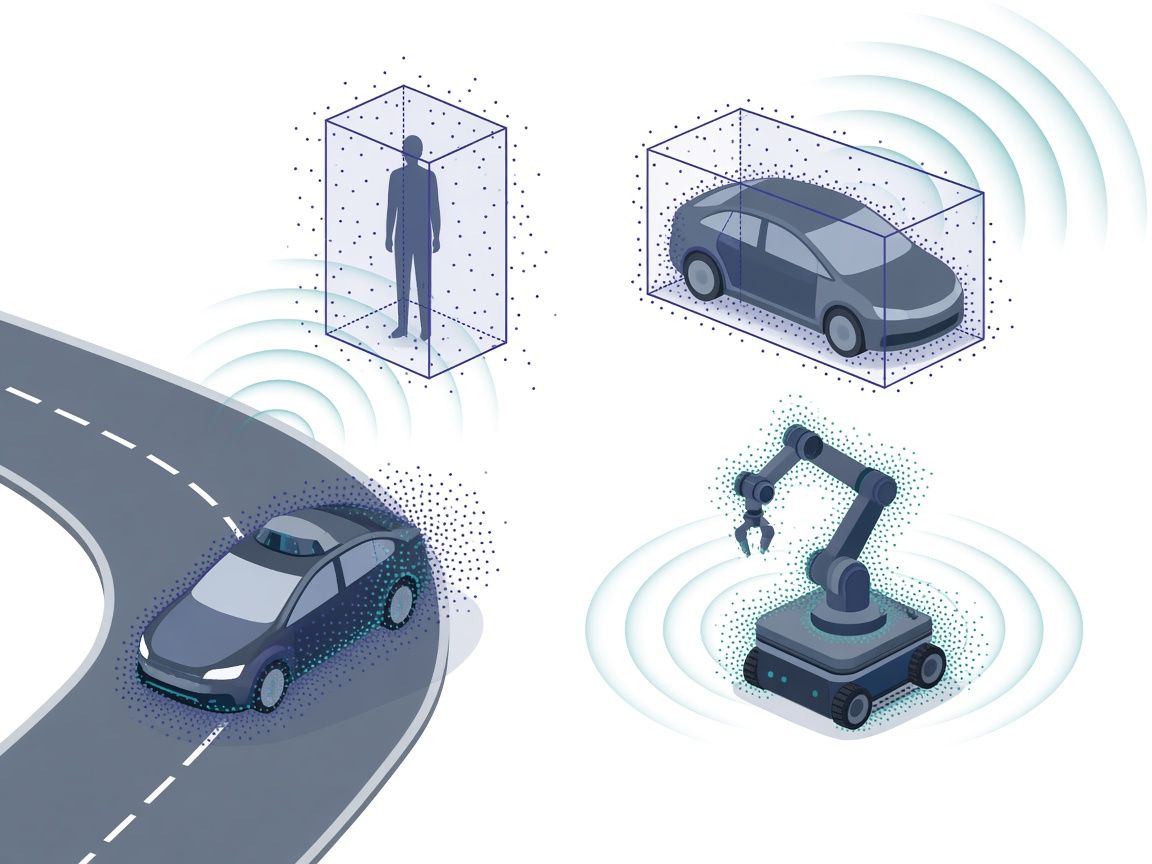
- Point-cloud cuboids and segmentation for vehicles, people and the wider scene.
- Camera and LiDAR fusion: labels that agree across sensors.
- Temporal tracking: consistent object identities across frames and sequences.
- Rare events: the unusual cases that matter most for safety.
- Robotics episode labelling: actions and outcomes across a robot's task.
LiDAR QA and correction

Hands-on LiDAR annotation, QA and correction, including MCAP files as used with Foxglove. We can review and correct existing point-cloud labels, whether they were produced by another vendor, an internal team or a model, as well as create new ones.
Multi-sensor work

Camera and LiDAR consistency, multi-sensor and robotics episode labelling, and related 3D tasks. The aim is one coherent picture of each scene: the same object carries the same identity and class in every sensor and every frame.
What we can do

We take on the full range of these tasks, from cuboids and segmentation to tracking and episode labelling, using the Computer Vision method, including programmes for which a public case study does not yet exist. Tell us the sensors, the taxonomy and the volume, and we will scope the work.
Delivery and tools

See Tools and Delivery for formats, handoff and MCAP handling, and How We Work for scope, calibration, review and acceptance.
Request a Project Quote

Brief us on your AV, robotics or LiDAR project: the sensors, file formats and tooling involved, and the labels you need.